IMX93 Camera Usage Guide
🚀 Introduction
This guide shows you how to get started using TechNexion camera modules on TechNexion IMX93 development kits. You must have the background knowledge to modify the kernel configuration, rebuild, and replace the kernel and the device tree source (DTS). This article is based on Yocto 6.0 (Wrynose) 2026Q3 Release with Linux kernel version 6.18.20-2.0.0.
📸 Supported Camera Modules
- TEVS Series
- TEVM Series
| Camera Series | Products |
|---|---|
| TEVS | TEVS-AR0144 TEVS-AR0145 TEVS-AR0234 TEVS-AR0235 TEVS-AR0246 TEVS-AR0521 TEVS-AR0522 TEVS-AR0544 TEVS-AR0821 TEVS-AR0822 TEVS-AR0830 TEVS-AR1335 TEVS-AR2020 |
| Camera Series | Products |
|---|---|
| TEVM | TEVM-AR0144 TEVM-AR0145 TEVM-AR0234 TEVM-AR0235 TEVM-AR0246 TEVM-AR0521 TEVM-AR0522 TEVM-AR0544 TEVM-AR0821 TEVM-AR0822 TEVM-AR0830 TEVM-AR1335 TEVM-AR2020 |
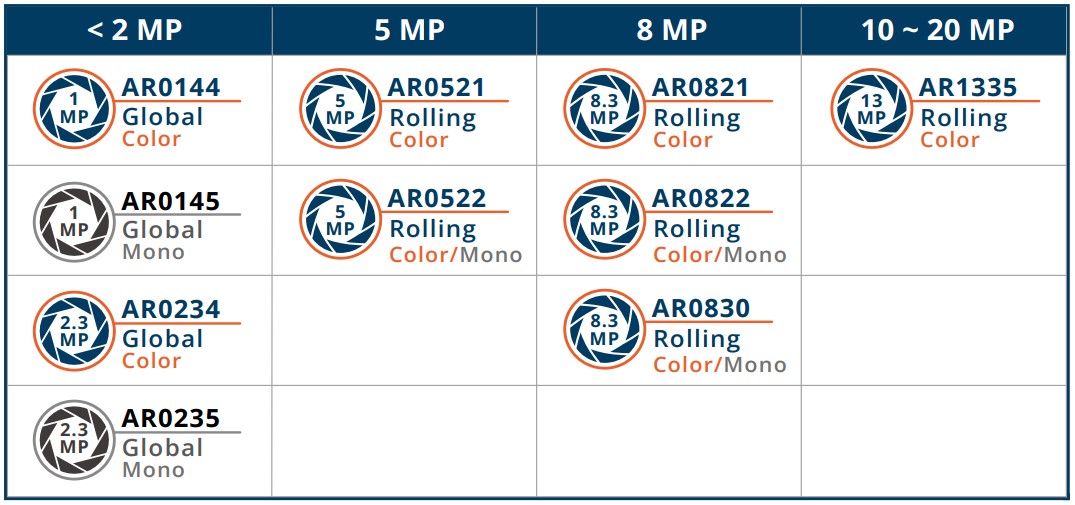
This article uses the TEVS-AR0822 as an example.
🧩 Supported Boards
| SoM | Board |
|---|---|
| EDM-IMX93 | EDM-WB-IMX93 |
| AXON-IMX93 | AXON-WB-IMX93 |
| PICO-IMX93 | PICO-SK |
🔧 Hardware Setup Instructions
1. Power Supply Preparation
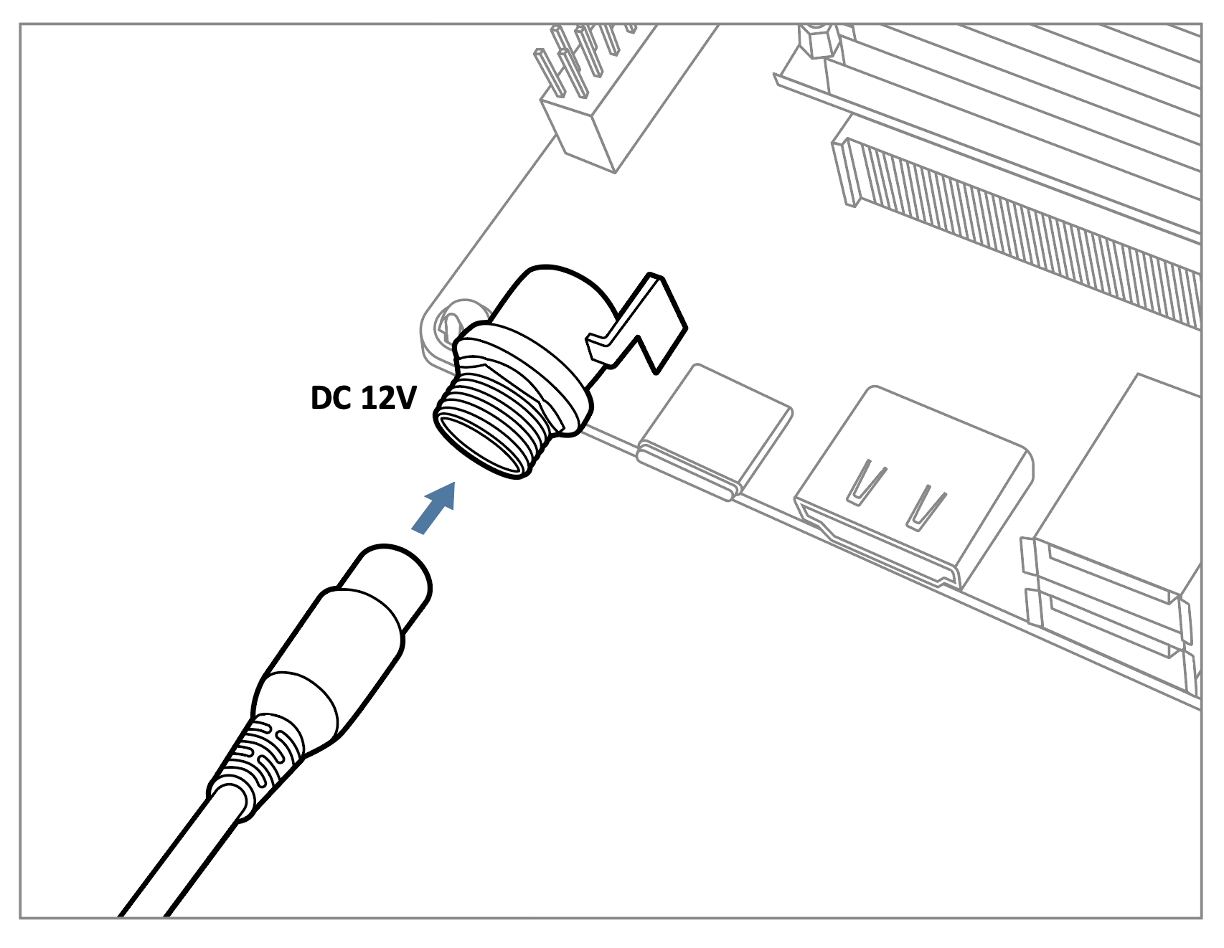
- Use a DC 5V or 12V power cable to supply power to the board.
- If you are using FPD-Link III SerDes, use a 12V power adapter (minimum 3A) connected through the barrel jack.
2. Debug Console Connection
- Prepare a USB-to-UART cable when connecting to a PC.
- Connect it to the CONSOLE1 connector.
3. Display Output Connection
- Prepare a panel for output display.
- Connect it to the LCD1 connector or LVDS1 connector on the board.
The provided DTBs include configuration for 10.1-inch and 15.6-inch LVDS display panels, as well as 5-inch and 8-inch LCD panels.
This output is useful for verifying the camera stream on screen.
4. Camera Interface (CSI) Overview
- The board has one MIPI CSI-2 interface, CSI1.
- It uses a 70-pin board-to-board connector manufactured by Hirose.
💻 Prepare Yocto demo image for testing TechNexion camera
Use a Yocto demo image that includes the required device tree blobs and camera drivers.
🔽 Downloading the Demo Image
The prebuilt demo image is available on TechNexion's download server.
Download Link
- EDM-IMX93
- AXON-IMX93
- PICO-IMX93
💾 Flashing the Image
Flash the image to e.MMC or an SD card using one of these methods:
Method 1. Using the UUU Tool
Set the board to Serial Download Mode before flashing.
Method 2. Using the U-Boot UMS Command
The board must boot a U-Boot version that supports the ums command.
Method 3. For Windows Users
🛠️ Build Yocto
TechNexion supports building a Yocto-based Linux image with the following kernel and branch.
📦 Supported Linux Kernel
| Linux Kernel Version | Yocto Branch |
|---|---|
| 6.18.20 | tn-imx_6.18.20_2.0.0-stable |
📁 Source and Build Instructions
- EDM-IMX93
- AXON-IMX93
- PICO-IMX93
📸 Camera Testing Instructions
🌳 Specify Camera DTBO in U-Boot
- Connect the debug console cable to the carrier board.
- Power on the board and interrupt boot when
Hit any key to stop autoboot:appears. - Set the camera overlay:
- CSI1 connector
u-boot=> setenv dtoverlay tevs
- Continue booting.
u-boot=> saveenv
u-boot=> boot
Append the display-panel overlay when you need on-screen camera output.
u-boot=> setenv dtoverlay=tevs vxt-vl050-070-8048nt
🎛️ Setup the media controller before camera streaming
Inspect the media topology:
$ media-ctl -p
Example output:
Media controller API version 6.18.20

Media device information
------------------------
driver          mxc-isi
model           FSL Capture Media Device
serial
bus info        platform:4ae40000.isi
hw revision     0x0
driver version  6.18.20

Device topology
- entity 1: crossbar (3 pads, 3 links, 1 route)
            type V4L2 subdev subtype Unknown flags 0
            device node name /dev/v4l-subdev0
        routes:
                0/0 -> 2/0 [ACTIVE]
        pad0: SINK,MUST_CONNECT
                [stream:0 fmt:UYVY8_1X16/1920x1080 field:none colorspace:srgb xfer:srgb ycbcr:601 quantization:lim-range]
                <- "csidev-4ae00000.csi":1 [ENABLED,IMMUTABLE]
        pad1: SINK,MUST_CONNECT
                <- "mxc_isi.output":0 [ENABLED,IMMUTABLE]
        pad2: SOURCE
                [stream:0 fmt:UYVY8_1X16/1920x1080 field:none colorspace:srgb xfer:srgb ycbcr:601 quantization:lim-range]
                -> "mxc_isi.0":0 [ENABLED,IMMUTABLE]

- entity 5: mxc_isi.0 (2 pads, 2 links, 0 routes)
            type V4L2 subdev subtype Unknown flags 0
            device node name /dev/v4l-subdev1
        pad0: SINK
                [stream:0 fmt:UYVY8_1X16/1920x1080 field:none colorspace:jpeg xfer:srgb ycbcr:601 quantization:full-range
                 compose.bounds:(0,0)/1920x1080
                 compose:(0,0)/1920x1080]
                <- "crossbar":2 [ENABLED,IMMUTABLE]
        pad1: SOURCE
                [stream:0 fmt:YUV8_1X24/1920x1080 field:none colorspace:jpeg xfer:srgb ycbcr:601 quantization:full-range
                 crop.bounds:(0,0)/1920x1080
                 crop:(0,0)/1920x1080]
                -> "mxc_isi.0.capture":0 [ENABLED,IMMUTABLE]

- entity 8: mxc_isi.0.capture (1 pad, 1 link)
            type Node subtype V4L flags 0
            device node name /dev/video0
        pad0: SINK
                <- "mxc_isi.0":1 [ENABLED,IMMUTABLE]

- entity 16: mxc_isi.output (1 pad, 1 link)
             type Node subtype V4L flags 0
        pad0: SOURCE
                -> "crossbar":1 [ENABLED,IMMUTABLE]

- entity 23: csidev-4ae00000.csi (2 pads, 2 links, 1 route)
             type V4L2 subdev subtype Unknown flags 0
             device node name /dev/v4l-subdev2
        routes:
                0/0 -> 1/0 [ACTIVE]
        pad0: SINK
                [stream:0 fmt:UYVY8_1X16/1920x1080 field:none colorspace:smpte170m xfer:709 ycbcr:601 quantization:lim-range]
                <- "tevs 1-0048":0 [ENABLED]
        pad1: SOURCE
                [stream:0 fmt:UYVY8_1X16/1920x1080 field:none colorspace:smpte170m xfer:709 ycbcr:601 quantization:lim-range]
                -> "crossbar":0 [ENABLED,IMMUTABLE]

- entity 28: tevs 1-0048 (1 pad, 1 link, 0 routes)
             type V4L2 subdev subtype Sensor flags 0
             device node name /dev/v4l-subdev3
        pad0: SOURCE
                [stream:0 fmt:UYVY8_1X16/640x480@1/60 field:none colorspace:srgb xfer:srgb ycbcr:601 quantization:full-range
                 crop.bounds:(0,0)/3840x2160
                 crop:(0,0)/640x480]
                -> "csidev-4ae00000.csi":0 [ENABLED]
The graph view can make the topology easier to understand.
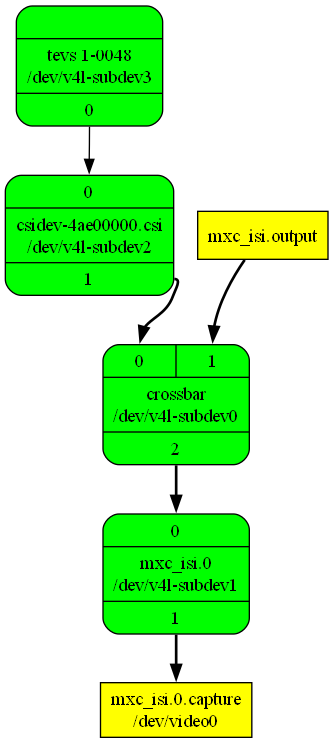
Generate the graph with:
$ media-ctl --print-dot > graph.dot
$ dot -Tpng graph.dot > graph.png
# Install Graphviz if needed:
# sudo apt-get install -y graphviz
Set the resolution and format of every media entity to match the camera output. Check supported formats, resolutions, and frame intervals:
# formats
$ v4l2-ctl -d /dev/v4l-subdev3 --list-subdev-mbus-codes
  ioctl: VIDIOC_SUBDEV_ENUM_MBUS_CODE (pad=0,stream=0)
        0x200f: MEDIA_BUS_FMT_UYVY8_1X16


# resolutions
$ v4l2-ctl -d /dev/v4l-subdev3 --list-subdev-framesize code=0x200f
  ioctl: VIDIOC_SUBDEV_ENUM_FRAME_SIZE (pad=0,stream=0)
        Size Range: 640x480 - 640x480
        Size Range: 1280x720 - 1280x720
        Size Range: 1920x1080 - 1920x1080
        Size Range: 2560x1440 - 2560x1440
        Size Range: 3840x2160 - 3840x2160


# frame interval of resolution
$ v4l2-ctl -d /dev/v4l-subdev3 --list-subdev-frameintervals width=640,height=480,code=0x200f
  ioctl: VIDIOC_SUBDEV_ENUM_FRAME_INTERVAL (pad=0,stream=0)
        Interval: 0.017s (60.000 fps)
        Interval: 0.033s (30.000 fps)
        Interval: 0.067s (15.000 fps)
        Interval: 0.100s (10.000 fps)

$ v4l2-ctl -d /dev/v4l-subdev3 --list-subdev-frameintervals width=1280,height=720,code=0x200f
  ioctl: VIDIOC_SUBDEV_ENUM_FRAME_INTERVAL (pad=0,stream=0)
        Interval: 0.017s (60.000 fps)
        Interval: 0.033s (30.000 fps)
        Interval: 0.067s (15.000 fps)
        Interval: 0.100s (10.000 fps)

$ v4l2-ctl -d /dev/v4l-subdev3 --list-subdev-frameintervals width=1920,height=1080,code=0x200f
  ioctl: VIDIOC_SUBDEV_ENUM_FRAME_INTERVAL (pad=0,stream=0)
        Interval: 0.017s (60.000 fps)
        Interval: 0.033s (30.000 fps)
        Interval: 0.067s (15.000 fps)
        Interval: 0.100s (10.000 fps)

$ v4l2-ctl -d /dev/v4l-subdev3 --list-subdev-frameintervals width=2560,height=1440,code=0x200f
  ioctl: VIDIOC_SUBDEV_ENUM_FRAME_INTERVAL (pad=0,stream=0)
        Interval: 0.033s (30.000 fps)
        Interval: 0.050s (20.000 fps)
        Interval: 0.067s (15.000 fps)
        Interval: 0.100s (10.000 fps)

$ v4l2-ctl -d /dev/v4l-subdev3 --list-subdev-frameintervals width=3840,height=2160,code=0x200f
  ioctl: VIDIOC_SUBDEV_ENUM_FRAME_INTERVAL (pad=0,stream=0)
        Interval: 0.067s (15.000 fps)
        Interval: 0.100s (10.000 fps)
        Interval: 0.125s (8.000 fps)
        Interval: 0.200s (5.000 fps)
Set the resolution to 1280×720, for example:
- Command Line
- Script
$ media-ctl -V "'crossbar':0 [fmt:UYVY8_1X16/1280x720 field:none colorspace:srgb xfer:srgb ycbcr:601]"
$ media-ctl -V "'mxc_isi.0':0 [fmt:UYVY8_1X16/1280x720 field:none colorspace:srgb xfer:srgb ycbcr:601]"
$ media-ctl -V "'csidev-4ae00000.csi':0 [fmt:UYVY8_1X16/1280x720 field:none colorspace:srgb xfer:srgb ycbcr:601]"
$ media-ctl -V "'tevs 1-0048':0 [fmt:UYVY8_1X16/1280x720@1/30 field:none colorspace:srgb xfer:srgb ycbcr:601]"
#!/bin/bash

# Define the format and resolution as a variable
mdev="/dev/media0"
mediactl="media-ctl -d $mdev"
cam="tevs 1-0048"
csi="csidev-4ae00000.csi"
isi="mxc_isi.0"
code="UYVY8_1X16"
width="1280"
height="720"
fps="1/30"
format="fmt:${code}/${width}x${height}@${fps} field:none"

# Function to run media-ctl commands with error handling
echo "Reset media controller..."
$mediactl -r
echo "Set media controller..."
$mediactl -l "\"$cam\":0 -> \"$csi\":0 [1]"
$mediactl -V "\"$cam\":0 [$format]"
$mediactl -V "\"$csi\":0/0 [$format]"
$mediactl -V "\"crossbar\":0 [$format]"
$mediactl -V "\"$isi\":0 [$format]"
This script includes enabling the link between the TEVS and CSI device.
🎥 Start Camera Video Stream via GStreamer
🎬 Launch GStreamer Pipeline
Replace <res_w> and <res_h> with the selected resolution:
$ gst-launch-1.0 v4l2src device=/dev/video0 ! \
  "video/x-raw, format=YUY2, width=<res_w>, height=<res_h>" ! \
  waylandsink sync=false
🚨 Troubleshooting
Check DTB Overlay in U-Boot
- CSI1 connector
  u-boot=> printenv dtoverlay
    dtoverlay=tevs vxt-vl050-070-8048nt
The vxt-vl050-070-8048nt overlay is for the 5-inch LCD display panel.
Verify Camera Initialization
  $ dmesg -t | grep tevs
    /soc@0/bus@44000000/i2c@44350000/tevs@48: Fixed dependency cycle(s) with /soc@0/bus@42800000/csi@4ae00000
    /soc@0/bus@42800000/csi@4ae00000: Fixed dependency cycle(s) with /soc@0/bus@44000000/i2c@44350000/tevs@48
    /soc@0/bus@44000000/i2c@44350000/tevs@48: Fixed dependency cycle(s) with /soc@0/bus@42800000/csi@4ae00000
    /soc@0/bus@44000000/i2c@44350000/tevs@48: Fixed dependency cycle(s) with /soc@0/bus@42800000/csi@4ae00000
    /soc@0/bus@42800000/csi@4ae00000: Fixed dependency cycle(s) with /soc@0/bus@44000000/i2c@44350000/tevs@48
    /soc@0/bus@44000000/i2c@44350000/tevs@48: Fixed dependency cycle(s) with /soc@0/bus@42800000/csi@4ae00000
    /soc@0/bus@42800000/csi@4ae00000: Fixed dependency cycle(s) with /soc@0/bus@44000000/i2c@44350000/tevs@48
    /soc@0/bus@42800000/csi@4ae00000: Fixed dependency cycle(s) with /soc@0/bus@44000000/i2c@44350000/tevs@48
    /soc@0/bus@44000000/i2c@44350000/tevs@48: Fixed dependency cycle(s) with /soc@0/bus@42800000/csi@4ae00000
    tevs 1-0048: tevs_probe() device node: tevs@48
    tevs 1-0048: Version:26.3.0.1
    tevs 1-0048: Product:TEVS-AR0822, HeaderVer:3, MIPI_Rate:800
    tevs 1-0048: Chip ID: 0x0F56
    tevs 1-0048: probe success
Confirm Board and Camera DTB
- EDM-IMX93
- AXON-IMX93
- PICO-IMX93
  $ dmesg -t | grep -i model
    Machine model: TechNexion EDM-IMX93 and WB baseboard
  $ dmesg -t | grep -i model
    Machine model: TechNexion AXON-IMX93 and WB baseboard
  $ dmesg -t | grep -i model
    Machine model: TechNexion PICO-IMX93 and SK baseboard
Check Available Video Devices
$ v4l2-ctl --list-devices
Example output:
mxc-isi-cap (platform:4ae40000.isi):
    /dev/video0
    /dev/video1
    /dev/media0